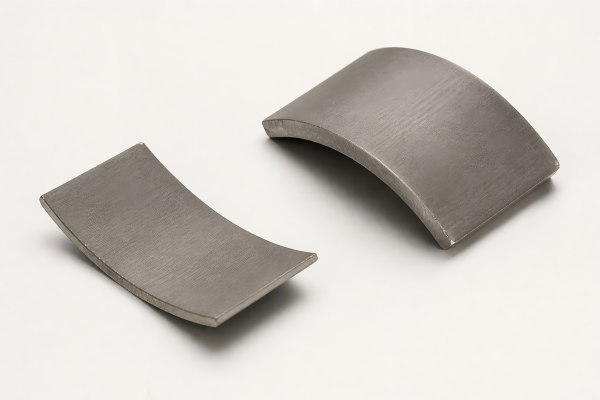
Compact Outrunner Platform
For compact joints, actuators and direct-drive mechanisms where axial length is tightly constrained.
- Installation envelope and shaft interface
- Continuous and peak torque points
- Speed range and commutation method
Ningbo Vanguard Technologies Co., Ltd
Compact external-rotor motor solutions for torque-dense motion systems.
Vanguard supports custom outrunner BLDC motor programs from magnetic circuit and component design through prototype validation and production planning. The supply scope can include magnets, rotor assemblies, stator laminations, windings and complete motor assemblies.
Start with the real torque-speed duty, voltage, package and cooling conditions. These inputs determine whether an external-rotor architecture is a good fit and how the motor should be validated.

The external rotor, permanent magnets, stator, windings and bearing system must work as one assembly.

Rotor bell, magnet retention, air-gap runout, balance and overspeed integrity.
Lamination geometry, winding connection, insulation, copper fill and thermal path.
Shaft or hub, bearing loads, mounting datums, cable routing and feedback devices.
Use these as enquiry starting points. Dimensions, ratings and protection level are confirmed for each project.
For compact joints, actuators and direct-drive mechanisms where axial length is tightly constrained.

For lower-speed applications that benefit from a larger effective rotor radius and direct torque output.

For motion systems requiring Hall sensing, encoder feedback or application-specific wiring.

For applications where a wider motor envelope can provide useful torque density and mechanical integration.

For projects needing coordinated magnets, rotor bell, stator, winding and balancing requirements.

For compact drive modules requiring lower output speed, higher output torque and a defined gearbox interface.
External-rotor motors can be useful where compact axial length and direct torque matter.

Assess joint torque, backdrivability, inertia, noise and the complete duty cycle. Motor, reduction stage and controller should be considered together.

Review shock loading, dust and moisture exposure, ambient temperature and serviceability for field equipment.

Define acceleration, wheel load, gradeability, operating noise and battery limits before selecting the drive architecture.
Connect magnetic, mechanical, thermal and manufacturing decisions from the beginning.
Compare direct-drive and geared concepts using torque-speed duty, package limits and control needs.
Coordinate pole count, magnet geometry, air gap, back iron, stator laminations and winding configuration.
Review the rotating outer shell, shaft or hub, bearings, retention, runout and overspeed margin.
Establish winding and magnet temperatures from copper loss, iron loss, duty cycle and available heat paths.
Define measurable acceptance criteria for torque, speed, efficiency, temperature rise, noise and vibration.
Align tooling, winding, rotor assembly, balancing, inspection and traceability for repeat manufacture.
Provide these requirements so the operating point can be reviewed on a consistent basis.
| Input | Information to Provide | Why It Matters |
|---|---|---|
| Voltage & Controller | DC bus range, current limit, PWM and commutation method | Defines the winding and electrical operating envelope. |
| Torque-Speed Duty | Continuous points, peak torque, peak duration and acceleration events | Separates sustained output from short-duration overload. |
| Package | Maximum diameter and length, shaft or hub, flange and cable exit | Sets the basic electromagnetic and mechanical architecture. |
| Dynamics | Permitted rotor inertia, response target, load inertia and transmission | External rotors can have higher inertia; the control response must be checked. |
| Thermal Conditions | Ambient temperature, duty cycle, mounting surface and airflow | Determines continuous torque and magnet temperature margin. |
| Environment | Dust, water, shock, vibration, corrosion and acoustic limits | Influences sealing, bearings, materials and validation tests. |
| Feedback & Safety | Hall sensors, encoder, brake, overspeed and guarding requirements | Defines control interfaces and rotating-shell risk controls. |
| Project Plan | Prototype quantity, validation standard, annual demand and dates | Aligns tooling, sourcing, test scope and production readiness. |
Mechanical output power: P (W) = T (N·m) × 2π × n (rpm) / 60. Continuous torque must be stated with the duty cycle and thermal conditions.
Motor Design
Connect electromagnetic, mechanical and thermal requirements from concept stage.
Motor R&DSimulation
Study magnetic performance and temperature risk before prototype release.
FEA SimulationPrototyping
Build samples around measurable torque, speed, efficiency and thermal targets.
Rapid PrototypingHelp Center
Send your operating points and installation envelope for review.
Contact VanguardIn an outrunner motor, the permanent-magnet rotor rotates around the stator. The larger effective rotor radius can support useful torque in a relatively short axial package, while the rotating outer shell requires careful mechanical and safety design.
An outrunner places the rotor outside the stator; an inrunner rotates inside it. The best choice depends on torque-speed duty, inertia, cooling, package geometry, bearing loads and the transmission architecture.
Provide DC bus voltage, continuous and peak torque-speed points, duty cycle, installation space, cooling, controller and feedback requirements, ambient conditions and expected annual quantity.
KV is commonly expressed as no-load speed per applied volt. It is related to the winding and motor constants, but it does not by itself define continuous torque, efficiency or thermal capability. Compare motors using the full operating point and duty cycle.
The project scope can include magnetic material selection, rotor and stator components, windings, prototype assemblies and production planning. The final scope is confirmed after reviewing the application and drawings.
Use agreed operating points and boundary conditions. Typical checks include torque-speed performance, current, efficiency, winding and magnet temperatures, cogging or torque ripple, noise, vibration, runout and overspeed integrity.
Send the voltage, torque-speed duty, package drawing, cooling conditions and planned quantity.