50 mm High-Torque Gearmotor
A larger spur gearbox platform for equipment requiring robust output torque and mounting.
- Typical voltage: 12-24 V
- Reference output: up to 100 W
- Output speed matched to ratio
Ningbo Vanguard Technologies Co., Ltd
Compact low-speed drive solutions with application-matched output torque.
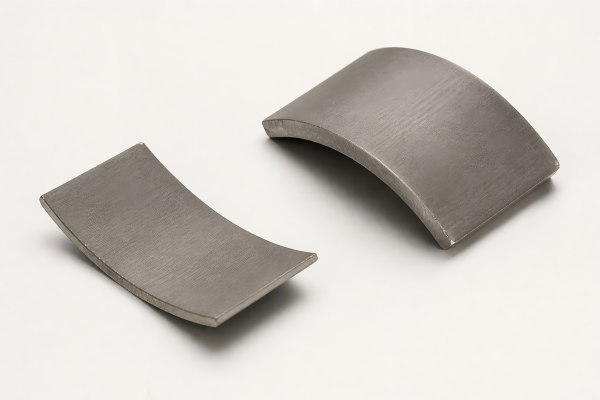
Vanguard supports custom DC geared motor projects from load definition and motor selection through gearbox component development, prototype validation and production planning. The scope can include magnets, motors, gears, shafts, housings, bearings, feedback devices and complete drive assemblies.
Reliable selection starts at the output shaft. Torque, speed, starts, reversals, stalls, duty cycle, efficiency, backlash, noise, life and external shaft loads must be considered together.

The motor, reduction stages, bearings, housing and output interface must be designed around the same load spectrum.

Voltage, winding, torque-speed curve, commutation, current limit and thermal behavior.
Gear stages, ratio, tooth loading, efficiency, backlash, material and lubrication.
Shaft, bearings, flange, seals, mounting datums and external radial or axial loads.
These common form factors are enquiry starting points. Final ratings depend on motor selection, reduction ratio, load cycle and validation conditions.
A larger spur gearbox platform for equipment requiring robust output torque and mounting.

A parallel-axis configuration for mechanisms needing a larger motor and offset output shaft.

A compact cylindrical drive for pumps, tools and automated mechanisms.

A smaller cylindrical format for compact equipment and light-duty positioning.

A flat-sided gearbox arrangement for controlled low-speed motion and repeatable mounting.

An economical platform for moderate torque and packaged automation mechanisms.

A configurable drive for valves, feeders, dispensers and mobile accessories.

A thin gearbox format for mechanisms with limited axial depth and an offset output.

A compact flat gearbox for slower output and application-specific mounting patterns.

For projects requiring an integrated motor, gearbox, connector, shaft and housing solution.
Geared DC drives are practical where simple control, reduction and compact mechanical integration matter.

Stable low-speed output, compact packaging and controllable flow make gearmotors useful for pump rollers and dosing mechanisms.
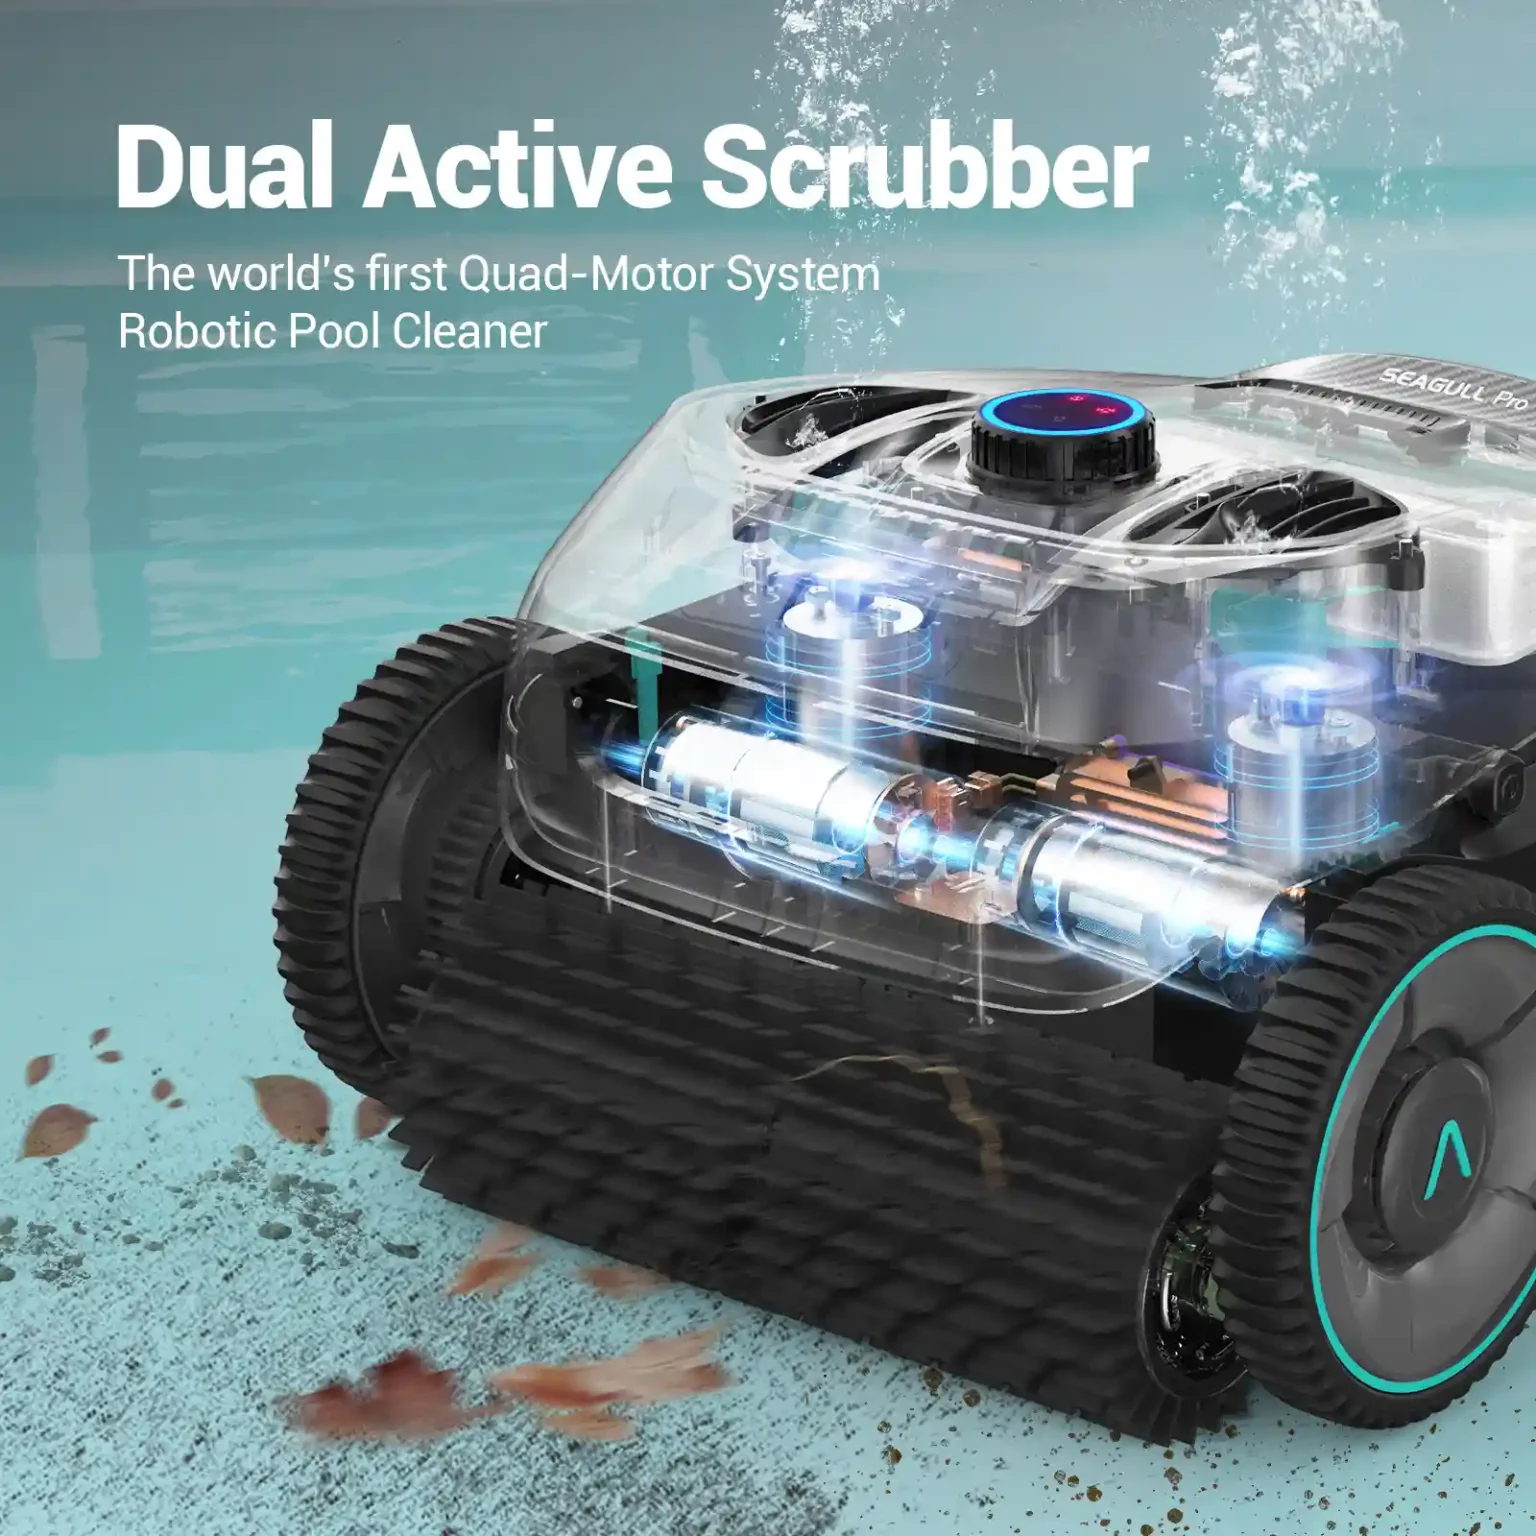
Wheel and brush drives require start torque, sealing, duty cycle, battery limits and shock loading to be assessed together.

Slow augers and feeders need controlled output speed, anti-jam strategy, stall protection and suitable gearbox durability.
Connect the output load, motor, geartrain and production controls before releasing samples.
Translate output torque, speed, starts, reversals, stalls and operating time into a usable load spectrum.
Compare spur, offset and flat gearbox concepts for ratio, efficiency, package, noise and cost.
Coordinate voltage, winding, motor speed, current limit and gear reduction around the loaded output point.
Review shaft, bearings, flange, housing, external loads, lubrication, seals and feedback interfaces.
Measure output torque and speed, current, temperature, backlash, efficiency, noise and durability.
Define gear inspection, grease quantity, end play, fastener torque and end-of-line functional testing.
Provide these inputs so candidate drive systems can be compared under consistent conditions.
| Input | Information to Provide | Engineering Impact |
|---|---|---|
| Output Duty | Continuous torque and speed, peak torque, start or stall events and cycle time | Defines motor size, ratio, gear loading and thermal margin. |
| Electrical Supply | Nominal and maximum voltage, current limit, driver and feedback interface | Determines motor winding and available input power. |
| Gearbox Layout | Inline or offset output, preferred ratio, permitted length and mounting orientation | Guides gear topology, stage count and housing design. |
| Precision & Noise | Backlash, repeatability, acoustic limit and acceptable torque ripple | Influences tooth quality, bearing support and assembly control. |
| Shaft Loads | Radial and axial load, overhung distance, shock, coupling and misalignment | Defines output shaft, bearings and housing stiffness. |
| Life & Thermal | Operating hours, starts, duty cycle, ambient temperature and cooling | Controls gear material, lubrication, motor temperature and wear margin. |
| Environment | Dust, moisture, chemicals, corrosion, sealing and cleanliness | Influences enclosure, grease, materials and validation tests. |
| Program Plan | Prototype quantity, acceptance criteria, annual volume and schedule | Aligns tooling, sourcing, inspection and production ramp. |
First-order output estimate: nout = nmotor / i, and Tout ≈ Tmotor × i × η. Verify efficiency and continuous or peak gearbox limits at the actual operating point.
Drive Development
Connect motor, gearbox, control and load requirements from concept stage.
Motor R&DPrototype Build
Verify torque, current, temperature, backlash, noise and life with measurable tests.
Rapid PrototypingProduction Readiness
Translate approved performance into gear, assembly and end-of-line controls.
Manufacturing Process ControlHelp Center
Send your output load cycle and installation drawing for an engineering review.
Contact VanguardIt combines a DC motor with a reduction gearbox. The gearbox lowers output speed and increases available output torque while changing package size, efficiency, backlash and reflected inertia.
Start with required output speed, torque and duty cycle. Compare these with the motor speed range and include gearbox efficiency. The ratio must also respect gear, shaft and bearing limits.
Not exactly. A first estimate is motor torque multiplied by ratio and gearbox efficiency. Continuous and peak output must remain below the allowable limits of every gear stage, carrier, shaft and bearing.
Life depends on the full load spectrum, gear material and geometry, lubrication, alignment, bearing loads, contamination, temperature, starts and shock events. A single nominal torque value is not enough.
The project scope can include Hall sensors, encoders, brakes, connectors, cables and customized shafts, flanges or housings. Feasibility is confirmed after reviewing the application.
Provide voltage, output torque and speed, peak or stall events, duty cycle, envelope drawing, shaft loads, backlash, noise, life, environment and annual quantity.
Send the voltage, output torque-speed duty, package drawing, ratio, life target and planned quantity.